World Model Arena
Train a world model. Dream a policy. Race it for real.
This is a hands-on competition where you build a world model of a driving simulator using IRIS or DIAMOND, train a reinforcement learning policy entirely inside your model's imagination, and then deploy it on the real MetaDrive simulator to see how well your dreams match reality. The goal: learn how world models work by actually building one.
Learn simulator physics from data
RL inside your model's imagination
Deploy on MetaDrive and compete
Four steps from zero to the leaderboard.
Fork the repo, clone it locally, and cd student_starter
Create a conda env and install dependencies
pip install -r ../requirements.txt
Run the 5-step pipeline: collect data, train WM, dream-train a policy, evaluate
One command evaluates and uploads to the leaderboard
python submit.py --tag my-v1
Watch the best dream-trained policies race on MetaDrive
Top submissions racing side by side
Ranked by ELO — computed from head-to-head route completion across all 5 maps.
How well does each world model predict the real simulator?
The dream-real gap measures whether your world model actually learned physics.
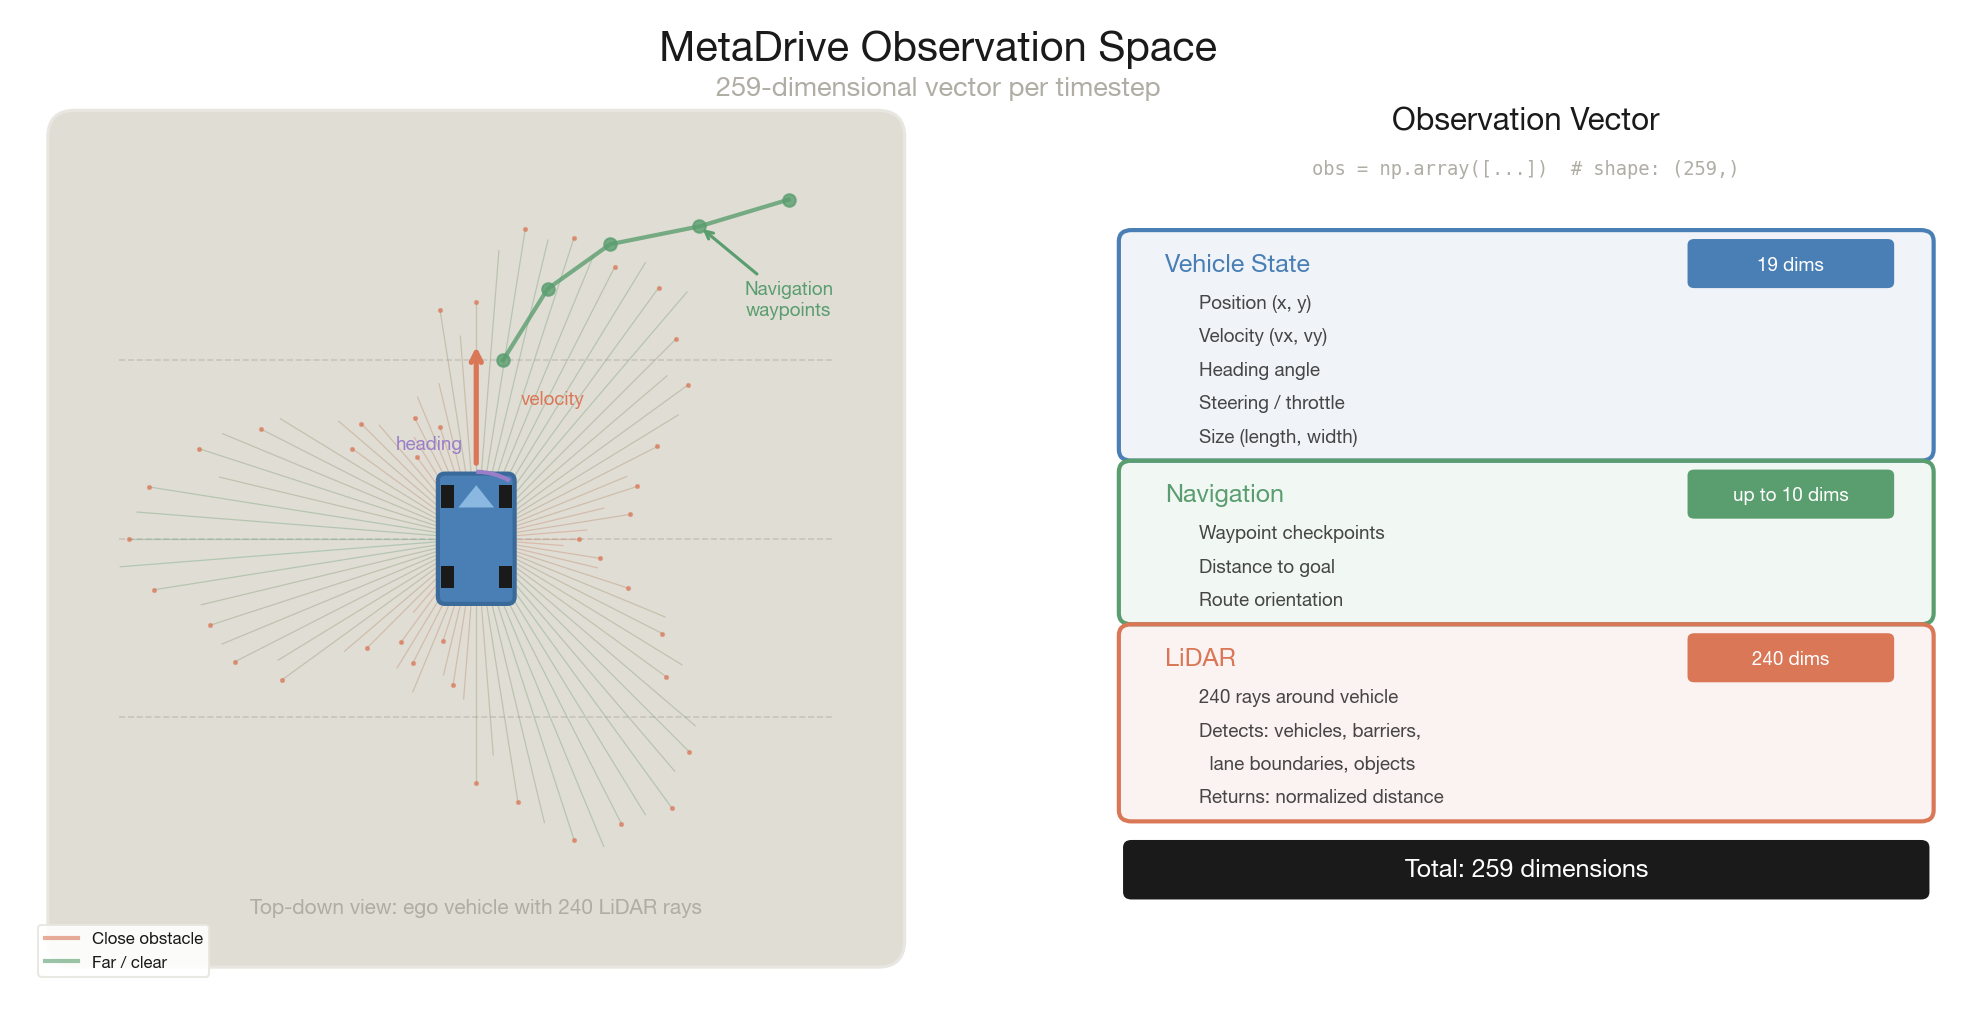
|dream_score − real_return| / max(|real_return|, 1)MetaDrive is a lightweight driving simulator built on Panda3D. Here's what your world model needs to learn.
259-dimensional vector
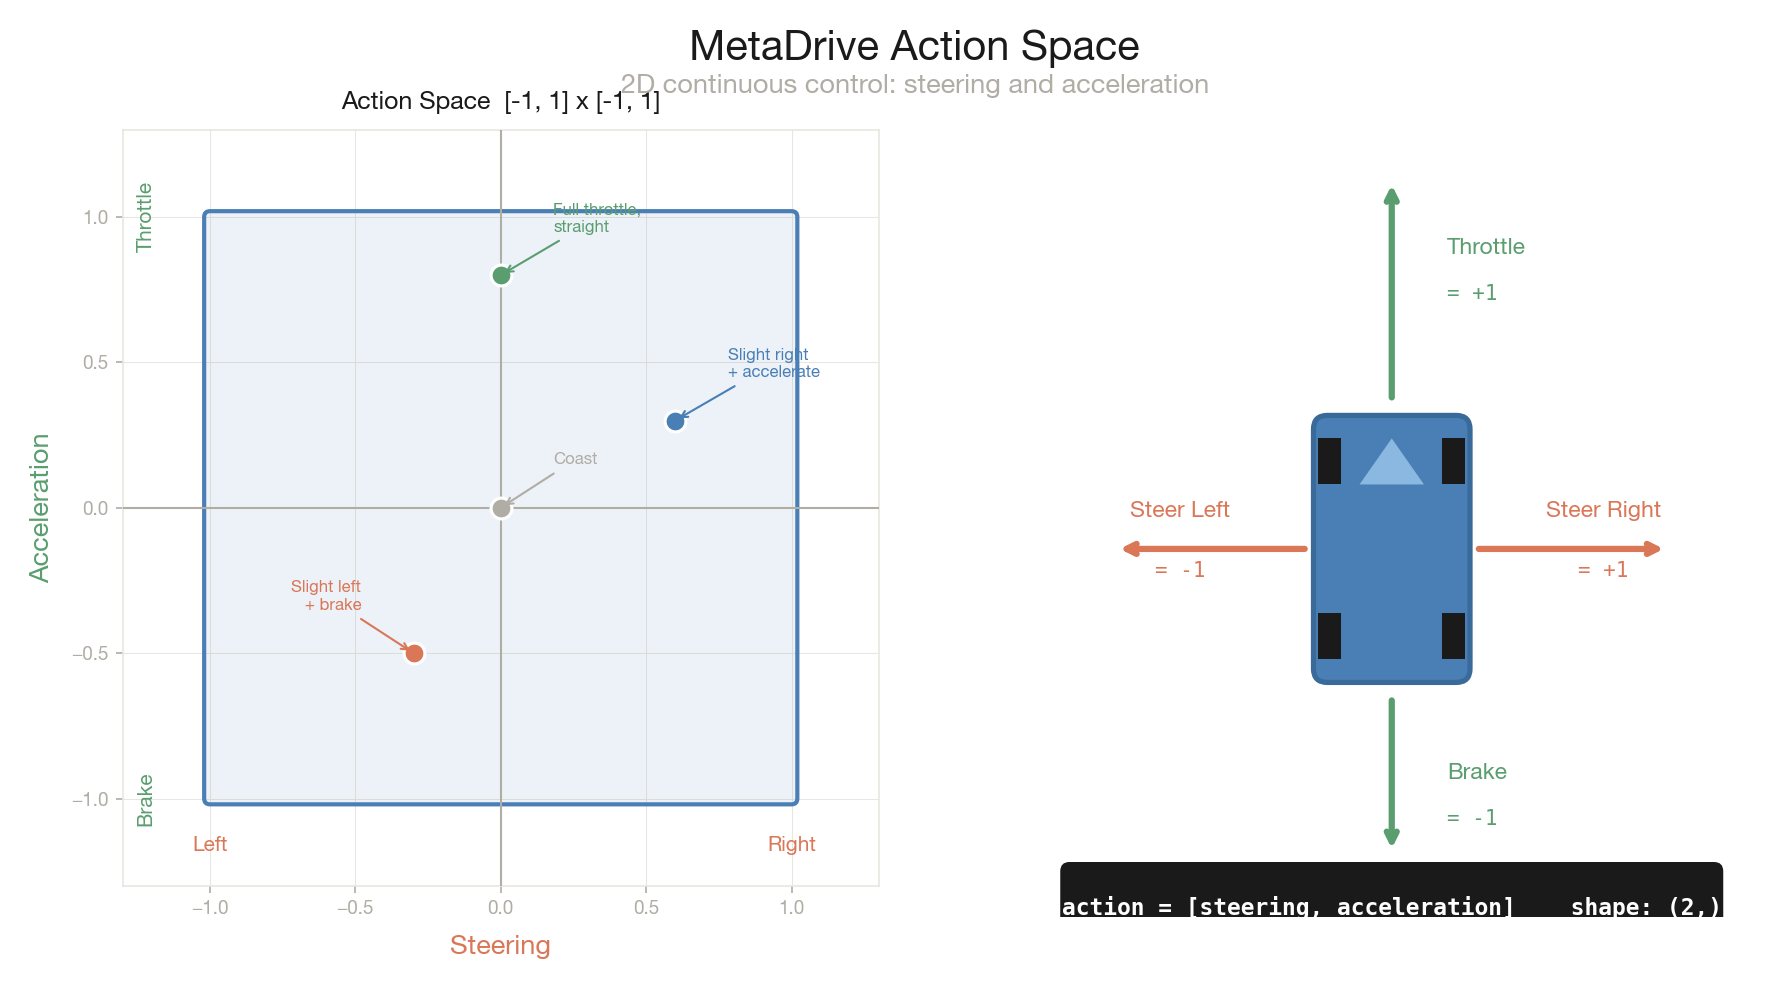
2D continuous
Your policy outputs these two values at each timestep. The world model must predict how the environment changes in response.
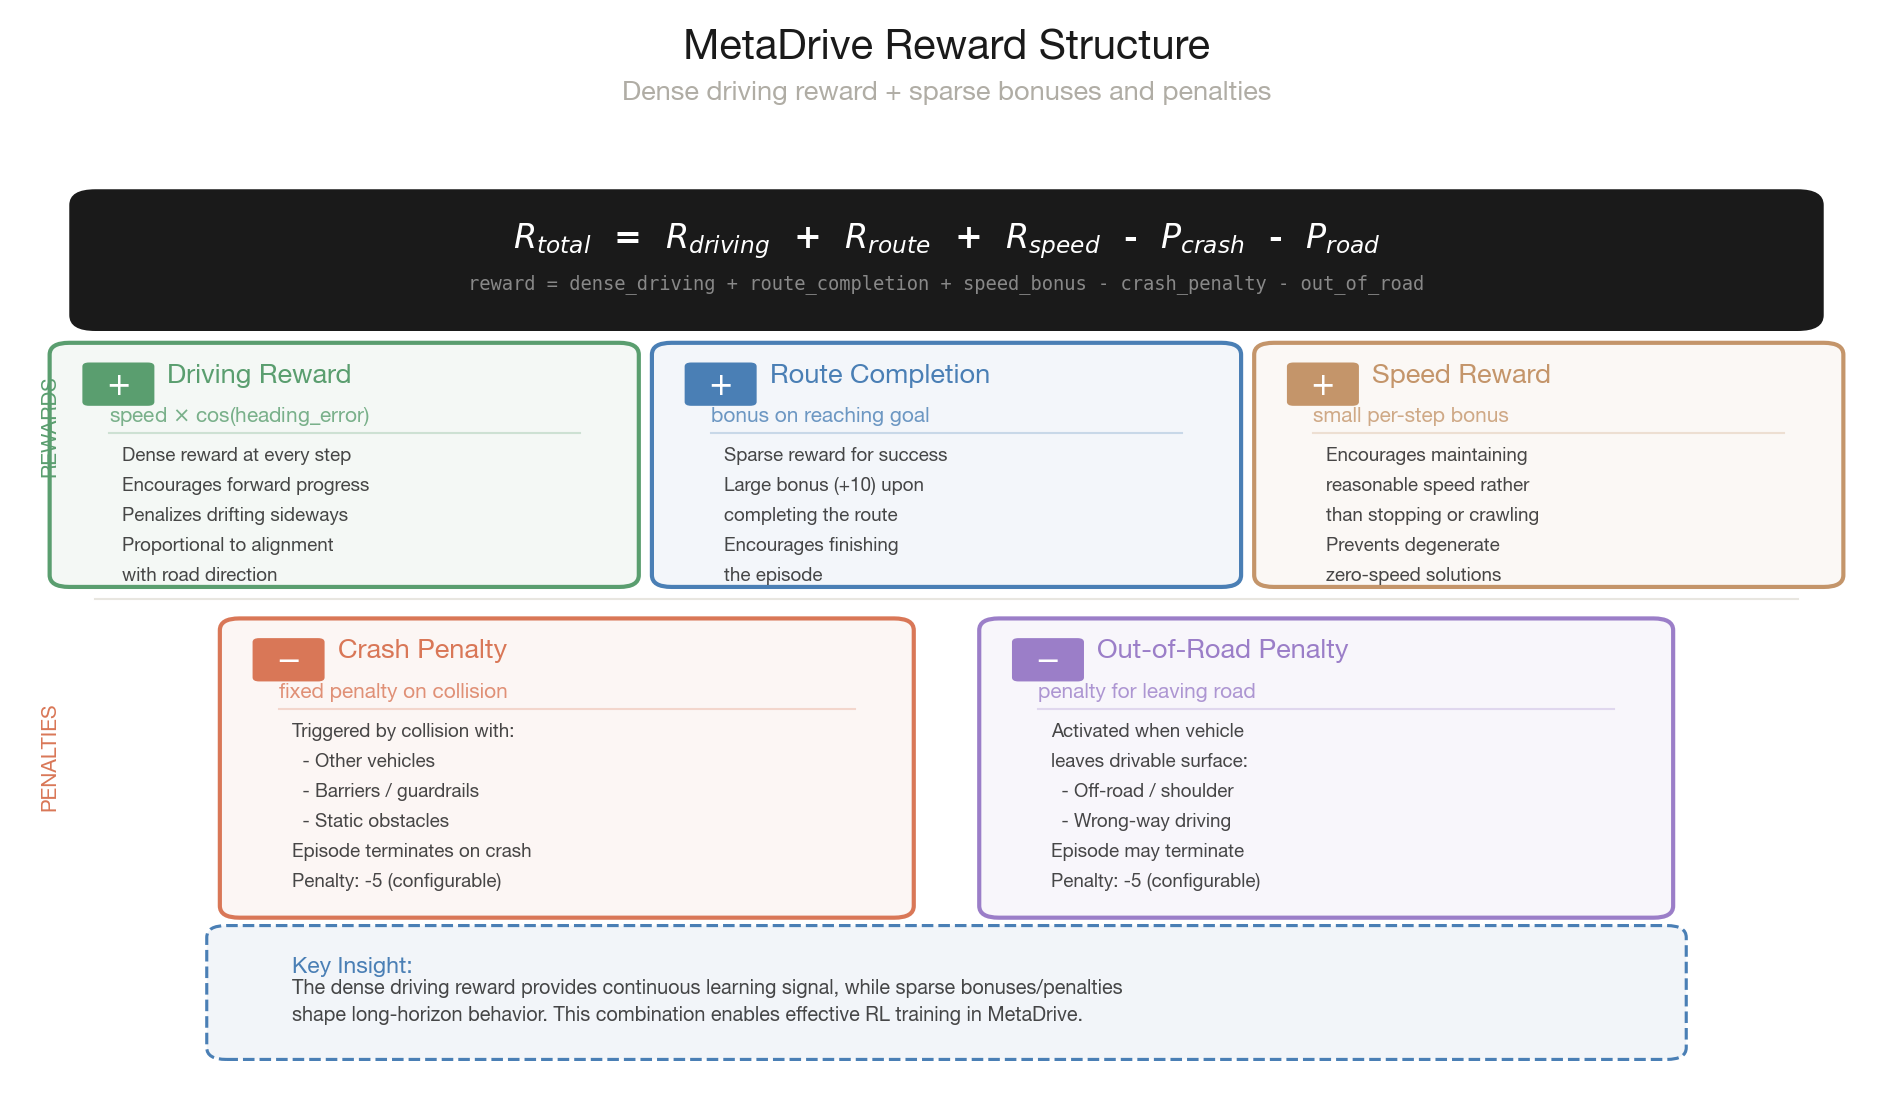
Dense + sparse signals
Your world model must learn to predict these rewards accurately. A model that gives free rewards creates policies that exploit hallucinations.
Every submission is tested on all 5 maps × 4 episodes. Route completion is averaged across all 20 runs.
Cinematic 3D captures from MetaDrive — chase-cam footage of policies navigating different track layouts.